Active Projects
Click into a project for documentation, specifications, and subsystem details.
Flying Wings: National Defence Hackathon
Competing in the Ops-2 category of this national defence innovation hackathon, this project involves building a quadcopter devoid of GPS signal reception capabilities. Upon receiving initial coordinates, the drone must autonomously navigate to five dynamic destination locations and successfully execute a return-to-home protocol.
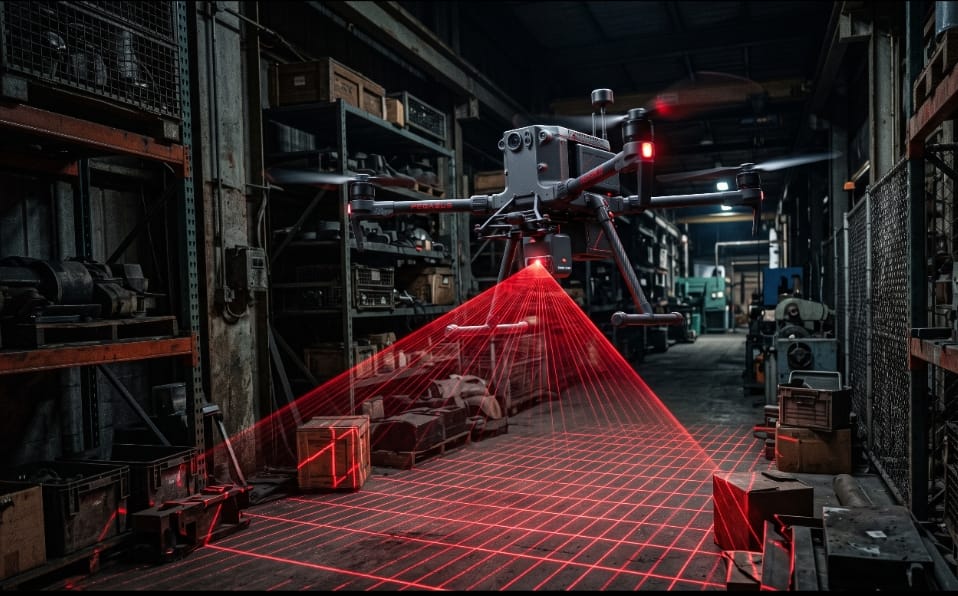
Project SYCLLA
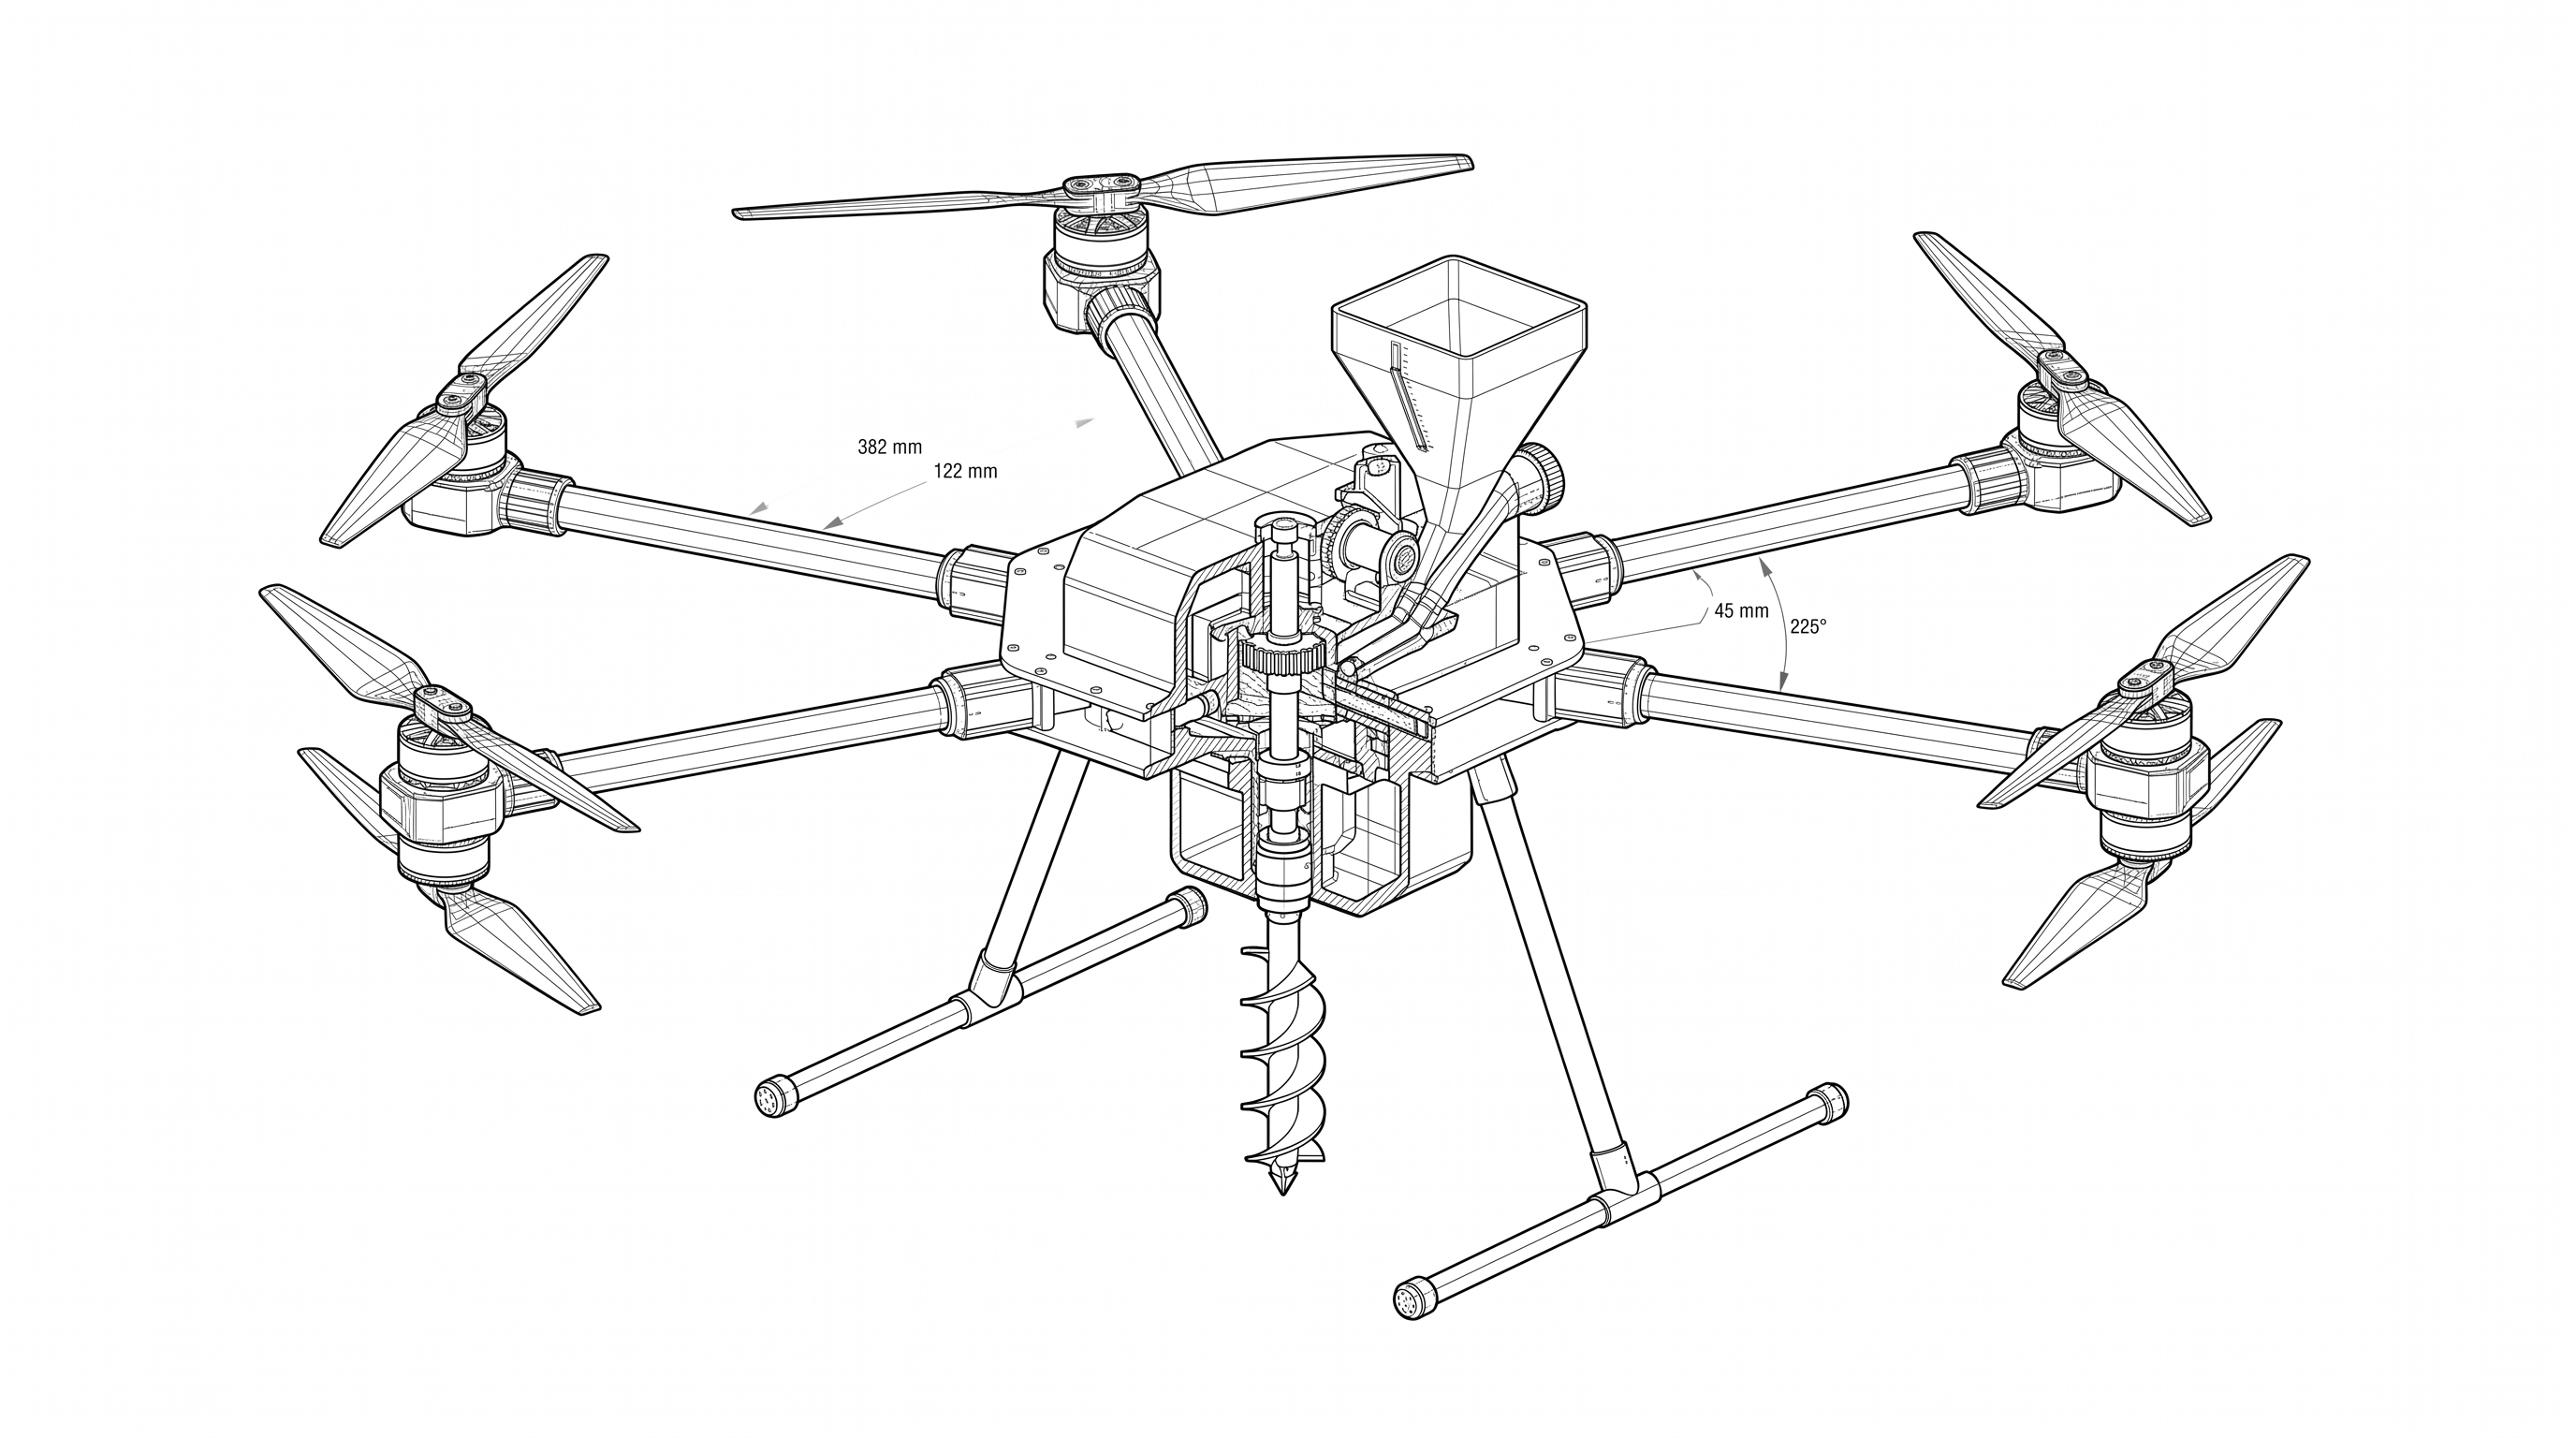
Conducted in collaboration with Georgia University, USA, this initiative moves beyond standard aerial surveying to focus on physical agricultural intervention. The project involves engineering a highly stabilized, autonomous UAV capable of navigating over soft, inaccessible paddy fields to perform precise rod insertions into the soil. This requires advanced payload balancing, sub-meter drilling and planting precision, and custom actuator mechanisms to ensure accurate placement without disrupting the surrounding crop environment.
Autonomous Underwater Vehicle
Electrical, Mechanical, Software subsystems. Immediate milestones: - Simple sensor integration - Transducer/echo-sounder - Pressure sensor Future Plan: - Autonomous path following using: - Doppler Velocity Log - Side Scanning SONAR - GPS (periodic on-surface fusion)