←RETURN TO PROJECTS/BUILD AGRICULTURAL-DRONE-COLLABORATION-GEORGIA-UNIVERSITY-4C073F
FIELD-TESTED PROTOTYPE
[ ACTIVE ]Autonomous Aerospace & Robotics Build

Project SYCLLA

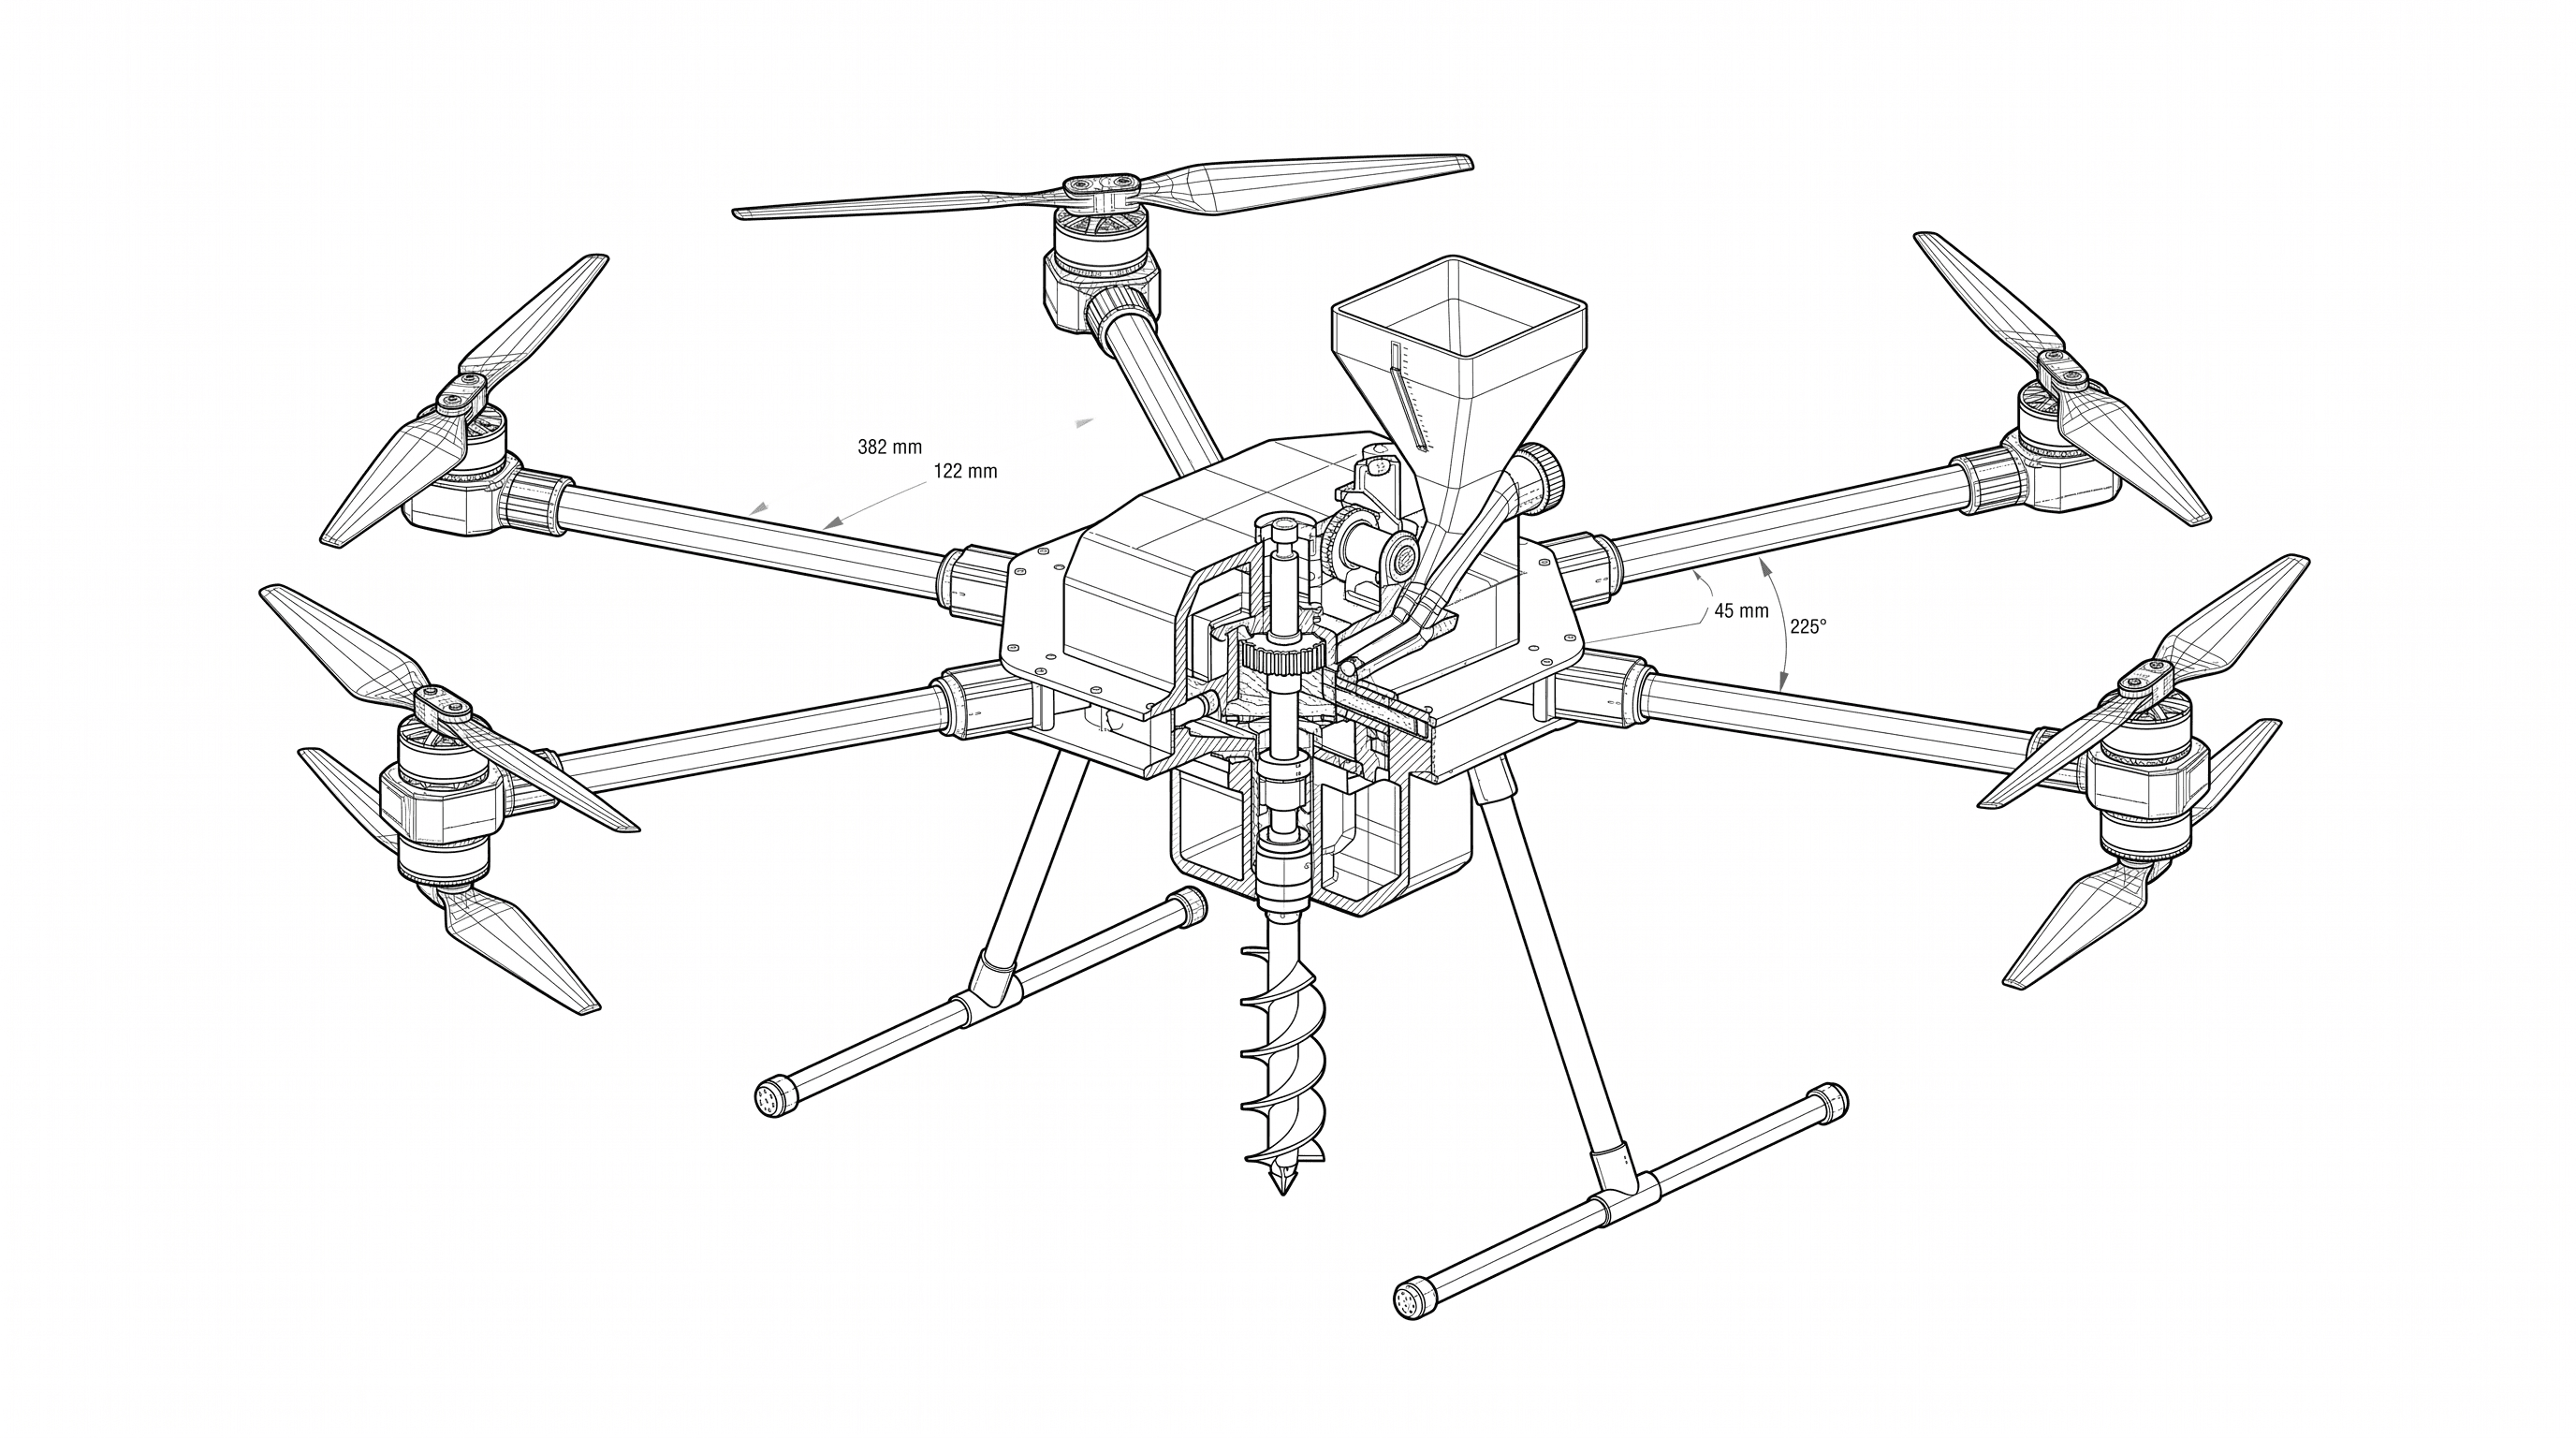
Project SCYLLA is an autonomous agricultural UAV engineered with a custom precision drilling and rod-planting payload mechanism designed to execute automated, high-accuracy aerial drilling.
PARTNER:IIST Pegasus UAV Club · Dept. of Space
DIVISION:Flight Autonomy & Avionics Team
ROUTER:/agricultural-drone-collaboration-georgia-university-4c073f
ACTIVE SUBSYSTEMS:PixhawkRaspberry PiLiDARCustom MechanismsPythonROS2ADAMS
Project SYCLLA
AIRFRAME VIEW · BUILD AGRICULTURAL-DRONE-COLLABORATION-GEORGIA-UNIVERSITY-4C073F
STATUS: ACTIVE
[ 01 -- Specifications ]

Performance Specifications

Bench-tested specifications, endurance parameters, and operational bounds.

Deployment Phase[ METRIC ]
ACTIVE

Current operational readiness tier

Subsystems Integrated[ METRIC ]
7Modules

Embedded sensors & controllers

Database Status[ METRIC ]
LIVE

Synchronized with Pegasus project database

[ 03 -- Mission ]

Operational Blueprint

Conducted in collaboration with Georgia University, USA, this initiative moves beyond standard aerial surveying to focus on physical agricultural intervention. The project involves engineering a highly stabilized, autonomous UAV capable of navigating over soft, inaccessible paddy fields to perform precise rod insertions into the soil. This requires advanced payload balancing, sub-meter drilling and planting precision, and custom actuator mechanisms to ensure accurate placement without disrupting the surrounding crop environment.

PRIMARY ENGINEERING MILESTONES & CAPABILITIES
[ OBJ-01 ]Autonomous Systems

Autonomous Mission Execution

Conducted in collaboration with Georgia University, USA, this initiative moves beyond standard aerial surveying to focus on physical agricultural intervention. The project involves engineering a highly stabilized, autonomous UAV capable of navigating over soft, inaccessible paddy fields to perform precise rod insertions into the soil. This requires advanced payload balancing, sub-meter drilling and planting precision, and custom actuator mechanisms to ensure accurate placement without disrupting the surrounding crop environment.

[ 02 -- Architecture ]

Avionics & Hardware Matrix

Subsystem flight controllers, edge companion compute, perception sensors, and communication systems.

01.Subsystem 01
Pixhawk
Custom Payload / Hardware Module
Integrated with flight controller and communication link.
02.Subsystem 02
Raspberry Pi
Custom Payload / Hardware Module
Integrated with flight controller and communication link.
03.Subsystem 03
LiDAR
Custom Payload / Hardware Module
Integrated with flight controller and communication link.
04.Subsystem 04
Custom Mechanisms
Custom Payload / Hardware Module
Integrated with flight controller and communication link.
05.Subsystem 05
Python
Custom Payload / Hardware Module
Integrated with flight controller and communication link.
06.Subsystem 06
ROS2
Custom Payload / Hardware Module
Integrated with flight controller and communication link.
07.Subsystem 07
ADAMS
Custom Payload / Hardware Module
Integrated with flight controller and communication link.
[ 04 -- Flight Logs ]

Flight Logs & Trials

Chronological deployment history, laboratory test phases, and verified field outcomes.

[ CADENCE 01 ]
Project Inception & Assembly
7/27/2026
VERIFIED
Recorded in active Pegasus projects directory.
[ 05 -- Weekly Notes ]

Weekly Sprint & Engineering Notes

Chronological weekly build progression, laboratory trial phases, and subsystem testing notes.

SPRINT WEEKS: 4
[ Week 04 ]// Oct 01 - Oct 07, 2026
STATUS:COMPLETED

Soil Probe Insertion Mechanism Field Calibration

Mounted CNC linear drive actuator and calibrated HX711 load cell feedback during automated soil probe penetrations in simulated wet clay terrain at IIST campus test plots.

[ KEY MILESTONES & SUBSYSTEM DELIVERABLES ]
✓Programmed automatic thrust compensation to counteract 180N ground reaction force
✓Validated automated probe depth detection with sub-centimeter repeatability
✓Integrated analog soil moisture and salinity sensor telemetry into QGroundControl
FLIGHT TESTING & TRIAL LOGS8 insertion trials · 1.5 flight hours logged
CHALLENGES & RESOLUTIONSFine-tuned stepper current limits to prevent motor stall in rocky subsoil.
[ Week 03 ]// Sep 24 - Sep 30, 2026
STATUS:COMPLETED

Centimeter Dual RTK-GNSS Rover-Base Station Integration

Paired Holybro H-RTK F9P helical rover with stationary base station. Achieved stable RTK Fixed lock under dense tree canopy and simulated agricultural boundary conditions.

[ KEY MILESTONES & SUBSYSTEM DELIVERABLES ]
✓Demonstrated ±1.5cm stationary hover position hold in 12-knot crosswinds
✓Configured u-blox ZED-F9P RTCM3 data link over RFD900x telemetry
✓Mapped 5-acre agricultural plot using automated grid waypoint planner
FLIGHT TESTING & TRIAL LOGS4 RTK mapping flights · 2.1 flight hours
CHALLENGES & RESOLUTIONSEliminated multipath interference by elevating base station antenna mast.
[ Week 02 ]// Sep 17 - Sep 23, 2026
STATUS:COMPLETED

Heavy-Lift Thrust & 5.5kg Payload Balancing

Installed dual 6S 16000mAh semi-solid LiPo power packs on the Tarot 650 hexacopter airframe. Tuned PX4 altitude control PID loops under varying dummy payload weights.

[ KEY MILESTONES & SUBSYSTEM DELIVERABLES ]
✓Achieved 22-minute hover endurance with full 5.5kg mechanical payload
✓Optimized motor PWM frequency for reduced thermal buildup in heavy-lift ESCs
✓Engineered quick-release carbon battery locking tray
FLIGHT TESTING & TRIAL LOGS7 flight duration trials
[ Week 01 ]// Sep 10 - Sep 16, 2026
STATUS:COMPLETED

Airframe Reinforcement & Actuator Mechanical Assembly

Reinforced folding arm joints of Tarot 650 frame with CNC aluminum clamps. Machined custom carbon fiber payload bay mounting bracket to house linear drive mechanism.

[ KEY MILESTONES & SUBSYSTEM DELIVERABLES ]
✓Designed and CNC-milled custom linear rod guide carriage
✓Tested stress limits under simulated 200N vertical thrust reactions
✓Installed isolated power rails for stepper motor drive to avoid avionics noise
FLIGHT TESTING & TRIAL LOGSStructural stress testing nominal
[ NEXT RESEARCH BUILD ]
PRJ-01 · FLIGHT-TESTED

Flying Wings: National Defence Hackathon
EXPLORE NEXT SPECS→
Flying Wings: National Defence Hackathon