
Flying Wings: National Defence Hackathon
Engineering a GPS-denied quadcopter capable of autonomous waypoint navigation for national defence applications.
Performance Specifications
Bench-tested specifications, endurance parameters, and operational bounds.
Current operational readiness tier
Embedded sensors & controllers
Synchronized with Pegasus project database
Operational Blueprint
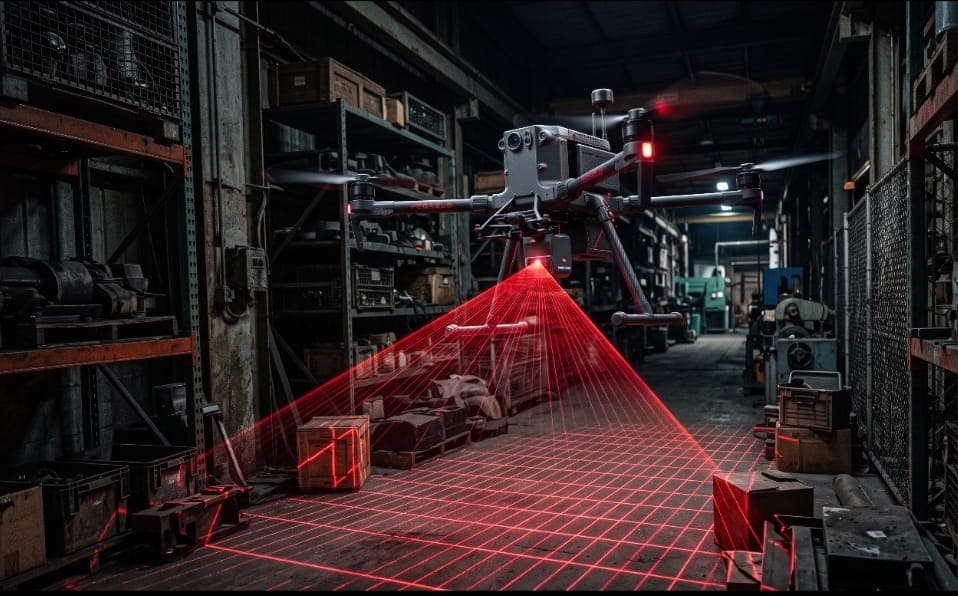
Competing in the Ops-2 category of this national defence innovation hackathon, this project involves building a quadcopter devoid of GPS signal reception capabilities. Upon receiving initial coordinates, the drone must autonomously navigate to five dynamic destination locations and successfully execute a return-to-home protocol.
Autonomous Mission Execution
Competing in the Ops-2 category of this national defence innovation hackathon, this project involves building a quadcopter devoid of GPS signal reception capabilities. Upon receiving initial coordinates, the drone must autonomously navigate to five dynamic destination locations and successfully execute a return-to-home protocol.
Avionics & Hardware Matrix
Subsystem flight controllers, edge companion compute, perception sensors, and communication systems.
Flight Logs & Trials
Chronological deployment history, laboratory test phases, and verified field outcomes.
Weekly Sprint & Engineering Notes
Chronological weekly build progression, laboratory trial phases, and subsystem testing notes.
Autonomous Waypoint Navigation & Obstacle Avoidance Validation
Successfully conducted multi-waypoint autonomous flight testing inside the simulated indoor avionics hangar. The Jetson Orin Nano processed real-time 3D depth point clouds to dodge simulated obstacles while maintaining zero-GPS position hold.
Stereo VIO Sensor Calibration & Precision Hover Trials
Integrated Intel RealSense D435i camera with downward TFmini LiDAR. Conducted 15-minute uninterrupted hover runs in the Avionics Bay to calibrate visual odometry scale factors.
RF Evasion Protocol & Low-Observability Telemetry Testing
Designed and tested burst telemetry protocols over ExpressLRS 2.4GHz to minimize electronic signature. Implemented fail-safe Return-to-Home routines on communication disruption.
Carbon Monocoque Airframe Rigging & Propulsion Bench Analysis
Assembled custom Toray 3K carbon fiber monocoque frame. Paired T-Motor F40 Pro IV motors with Tekko32 ESCs on thrust stand to evaluate power efficiency and thermal dissipation.
Flying Wings: National Defence Hackathon